At Servo7, we build robots in the field every day. Along the way, we build tools to solve the problems we keep running into. Real-to-Sim is one of them. We are sharing it because we are tired of seeing other robotics teams solve the same problems from scratch. Roboticists should spend their time on hard problems, not reinventing tooling.
The problem
You are a robotics engineer. You have seen dozens of robots working in dozens of facilities. You know what a robot looks like operating in a tight aisle, on a production floor, next to a conveyor. That context is obvious to you.
The facility you are talking to does not have that context. They might have seen one or two demos, maybe a YouTube video. When you tell them “we can deploy a robot here,” they are picturing something abstract. They cannot see it.
Closing a robotics deal gets a lot easier when you can show a video of your robot, operating in their specific facility, doing the actual task. Not a generic demo. Their facility.
The problem is that building a sim environment from scratch for every sales conversation is too slow. You have a call next week. You do not have time to model the place.
The tool
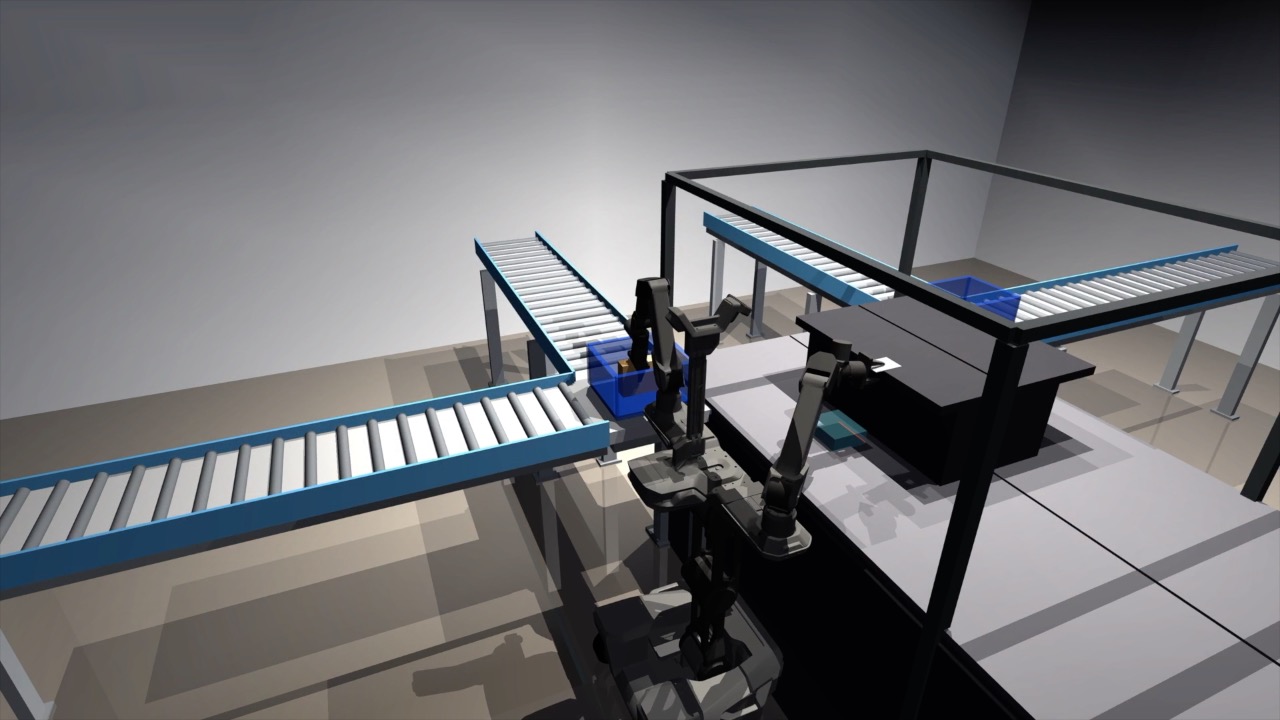
Real-to-Sim takes a video of the facility as input. A walkthrough, a phone recording, anything. It processes the footage and reconstructs the environment as a simulation. You drop in your robot, set up the task, and record a demo video.
The output is a short video your customer can watch. Their facility. Your robot. The specific task they care about.
This compresses what used to take weeks into something you can turn around before a follow-up call. It is also useful internally, for testing robot behavior in environments close to what you will actually deploy in.
The tool is part of a growing set of open dev tools we are releasing from our internal stack. If you are building robots and want to use it or contribute, reach out.
Want to know more?
We are sharing what we build. Get in touch if this might be useful to you.
We'll be in touch soon.
Something went wrong. Try again.